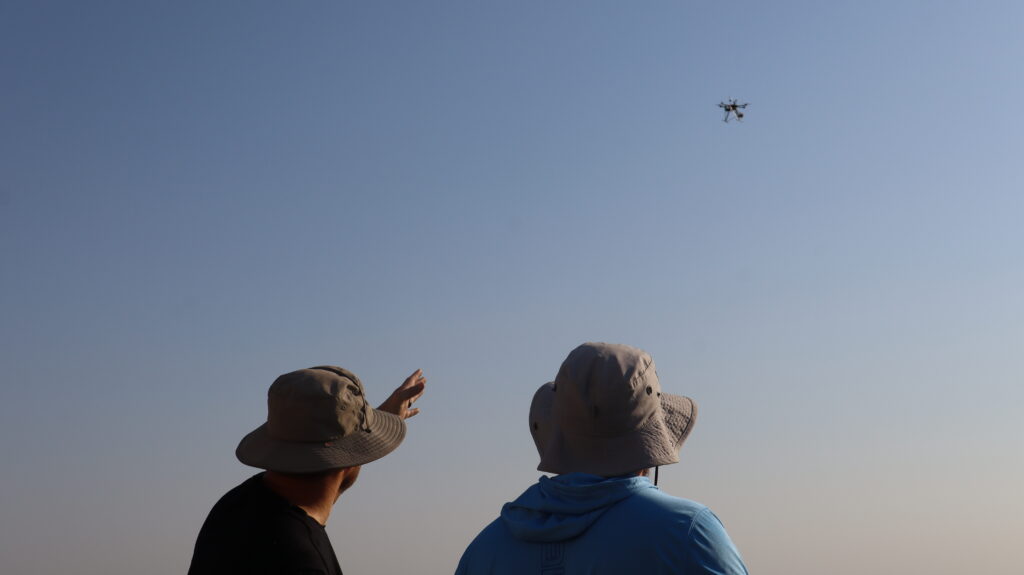
Vigilant Aerospace Systems has completed another series of ground and flight tests focused on improving airborne radar tracking for its FlightHorizon PILOT-M onboard detect-and-avoid system.
FlightHorizon PILOT-M uses a direct connection to the autopilot for ownship location and status, an ADS-B In receiver and one or more onboard radars to track cooperative and non-cooperative aircraft, evaluate potential conflicts and provide avoidance guidance to a remote pilot or to the autopilot.
The testing is part of a $1 million development project supported in part by the Oklahoma Center for the Advancement of Science and Technology (OCAST) through its Industry Innovation Program. The project is being conducted in collaboration with Oklahoma State University’s Oklahoma Aerospace Institute for Research and Education (OAIRE).
The latest work evaluated how effectively the system filters radar clutter when the sensor is exposed to movement and vibration. These conditions are unavoidable when radar is installed on an uncrewed aircraft system (UAS), making them an important consideration for reliable onboard detect-and-avoid (DAA).
“We know from ongoing and recent discussions with multiple advanced air mobility companies that they find radar integration for detect-and-avoid and safety to be challenging. This is a functional area in FlightHorizon PILOT where we have been pioneers for several years, including controlling critical NASA patents that support our work. Using radar on a moving platform to feed data to and inform an automated, dynamic detect-and-avoid algorithm is challenging, but we have proved through multiple installations and projects that it can work and become part of a safety system for routine flight over long distances,” said Kraettli L. Epperson, Vigilant Aerospace CEO.
“That’s why we released FlightHorizon PILOT-M and continue to work with partners, UAS manufacturers, military commands and government operators to deliver a system that fills this important technical gap for onboard DAA and solves their safety problem.”
Radar Filtering Under Controlled Motion
Radar installed on an aircraft must distinguish real airborne traffic from unwanted returns generated by the ground, vegetation, buildings and other objects. Sensor movement and vibration add complexity because stationary objects can appear to shift between radar updates. Effective filtering must remove these unwanted tracks without filtering out actual aircraft.
The filtering process used in FlightHorizon PILOT-M rejects unwanted tracks using multiple filters and track analysis algorithms. The system tested in this program with OAIRE successfully tracked multiple Cessna 172 aircraft from multiple kilometers away and overal several kilometers.
Improving Filtering Under Flight Conditions
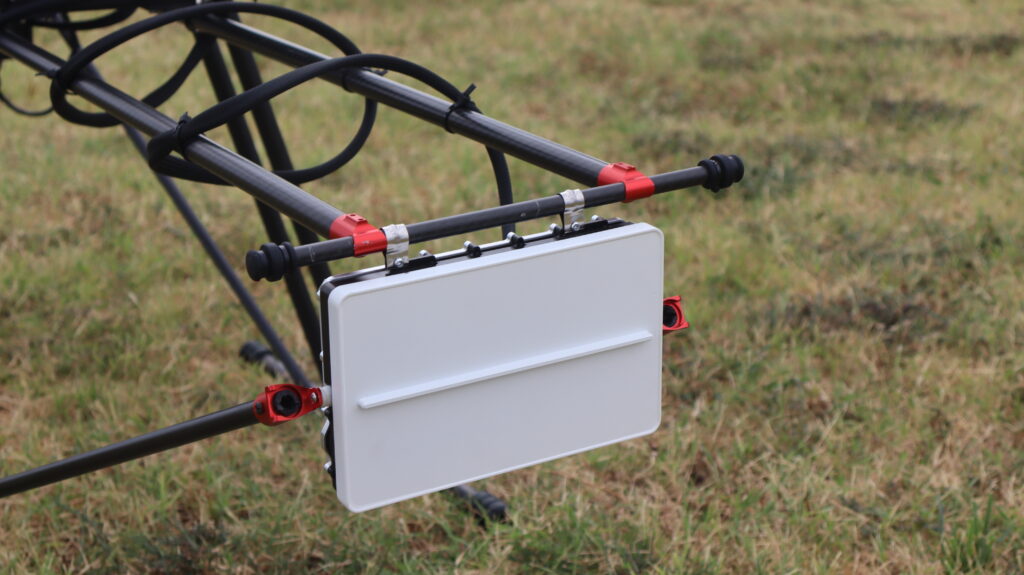
The team installed the radar and supporting systems on an airborne test platform to refine the filtering process under flight conditions. This work exercised the onboard sensors, computing, communications, data flow and power systems together in a dynamic operating environment.
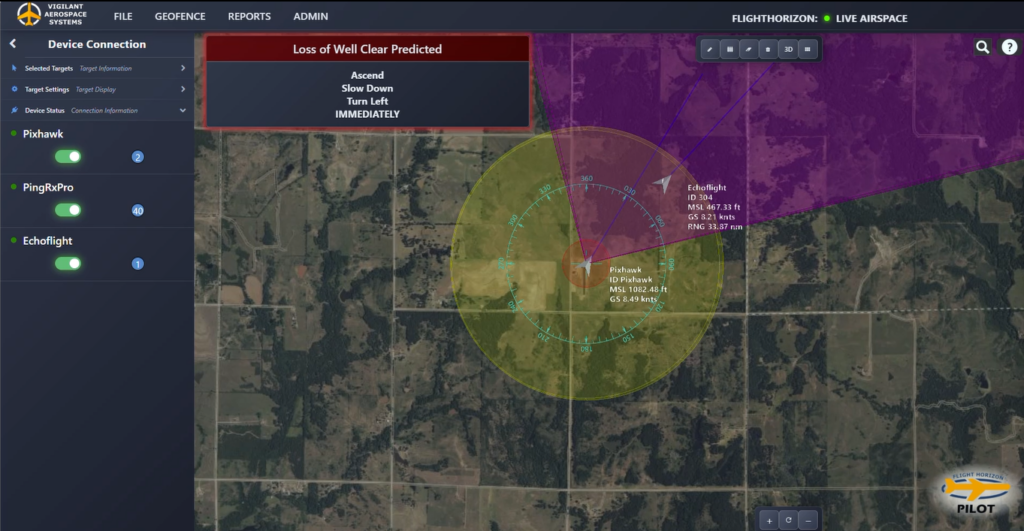
During the flight, FlightHorizon PILOT-M processed radar data onboard the aircraft and relayed radar tracks to the ground display. The ground system runs special software, FlightHorizon PILOT Viewer, to display and monitor what the onboard system is seeing and doing, which can be invaluable for both research and flight operations.
The test provided additional data for refining how the system removes unwanted returns caused by aircraft vibration, movement and changes in the radar’s position relative to the ground.
This work builds on the system’s existing filtering capabilities by accounting for a wider range of motion and vibration conditions. Continued refinement will support a consistent air traffic picture across different aircraft platforms and operating environments.
The results will inform the next phase of integration and testing on additional models of larger fixed-wing UAS.
Supporting Onboard Detect-and-Avoid Advancements
This testing advances the broader FlightHorizon PILOT product family, which is designed to provide onboard air traffic tracking, conflict evaluation and avoidance guidance for UAS.
FlightHorizon PILOT-C provides cooperative traffic awareness using ADS-B In, while FlightHorizon PILOT-M adds onboard radar for tracking non-cooperative aircraft. Because the current tests focus on airborne radar performance, they directly support development of the radar-enabled PILOT-M configuration.
The latest work builds on earlier project milestones over the last several years involving autopilot integration, onboard computing, cooperative and non-cooperative traffic inputs, ground-station displays and testing on multirotor and fixed-wing aircraft. Vigilant Aerospace previously published a project and flight-testing update describing these developments.
The next stages of the project will continue tuning the radar-filtering process and preparing the system for integration and flights on larger UAS. Data collected through this work will support system refinement, platform integration and continued evaluation against applicable DAA technical standards.
About the Oklahoma Center for the Advancement of Science and Technology
The Oklahoma Center for the Advancement of Science and Technology is Oklahoma’s state agency focused on technology-based economic development. Its Industry Innovation Program provides funding for Oklahoma companies developing technologies with commercial applications and potential economic impact in fields including aerospace, autonomous systems and defense.
About the Oklahoma Aerospace Institute for Research and Education
The Oklahoma Aerospace Institute for Research and Education is an institute within Oklahoma State University that coordinates aerospace research, testing and workforce-development programs. OAIRE supports partnerships among industry, academia, government and the military, with capabilities spanning autonomous systems, advanced air mobility, airspace integration and flight testing.
 Vigilant Aerospace is the leading developer of multi-sensor detect-and-avoid and airspace management software for uncrewed aircraft systems (UAS or drones). The company’s product, FlightHorizon, is based on two NASA patents and uses data from multiple sources to display a real-time picture of the air traffic around a UAS and to provide automatic avoidance maneuvers to prevent collisions. The software is designed to meet industry technical standards, to provide automatic safety and to allow UAS to safely fly beyond the sight of the pilot. The software has won multiple industry awards and the company has had contracts and users at NASA, the FAA, the U.S. Department of Defense and with a variety of drone development programs. Visit our website at www.VigilantAerospace.com